matek ap periph can l4 bm digital power monitor
New

Matek AP_Periph CAN-L4-BM Digital Power Monitor

About Matek AP_Periph CAN-L4-BM CAN Digital Power Monitor

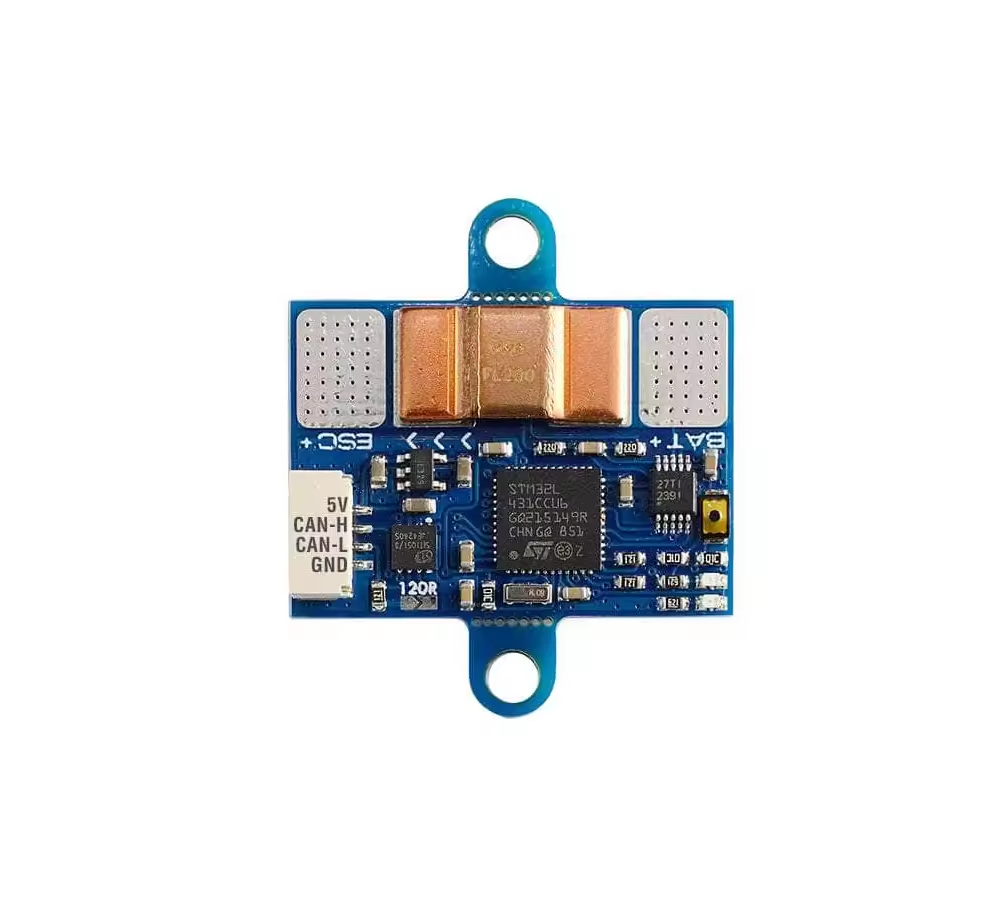
The Matek AP_Periph CAN-L4-BM CAN Digital Power Monitor offers ultra-precise monitoring for your drone needs. It features a low-power resistant path of 200μΩ, providing high efficiency in power consumption. No calibration is required and DroneCAN protocol offers convenient current & bus voltage readouts. Enjoy precision monitoring and convenience with the AP_Periph CAN CAN-L4-BM.

$30 Off Orders $499+
$15 Off Orders $249+
Collect
$ 24.99
5 | 11Sold
Options (1)
fall into big savings pc gift
In Stock Expected ship within 5 days after order.
FedEx
USPS
  • Free Shipping Over $79 | Save on Orders $79+
  • 24-Month Warranty | 2 Years Full Protection
  • 30-Day Returns From Shipment | 7-Day No-Reason Returns
  • 24h Support Response | 24h Fast Support Guarantee
Top highlights
  • Built with TI INA239 and STM32L431 running ArduPilot AP_Periph firmware, it delivers accurate real-time voltage and current data over CAN without analog calibration.
  • Supports up to 0–85V input voltage and 0–204.8A current sensing (approx. 150A continuous), suitable for FPV, multirotor, and medium-to-large UAV power systems.
  • Uses DroneCAN protocol for direct communication with flight controllers, ensuring stable data transmission with strong anti-interference performance.
  • Features ultra-low resistance (approx. 200μΩ) current path design, with voltage accuracy of ±0.1% and current accuracy of ±2% for professional-grade telemetry.
  • Ultra-compact size (approx. 30×22×3mm) and only ~4g weight. Powered by 5V (4.5–5.5V range) with DFU firmware upgrade support for ArduPilot ecosystems.
Payment | Every order you place with us is safe & secure

Share
Tips

● The big pad on the bottom side is a dead pad. No any circuit network on it.

● Solder the positive wires as close as possible to both sides of the current sensing resistor.

● 2 ears for mounting can be cut off if you don’t need it.

● If the CAN wires are too long, bridge the “120R” jumper.


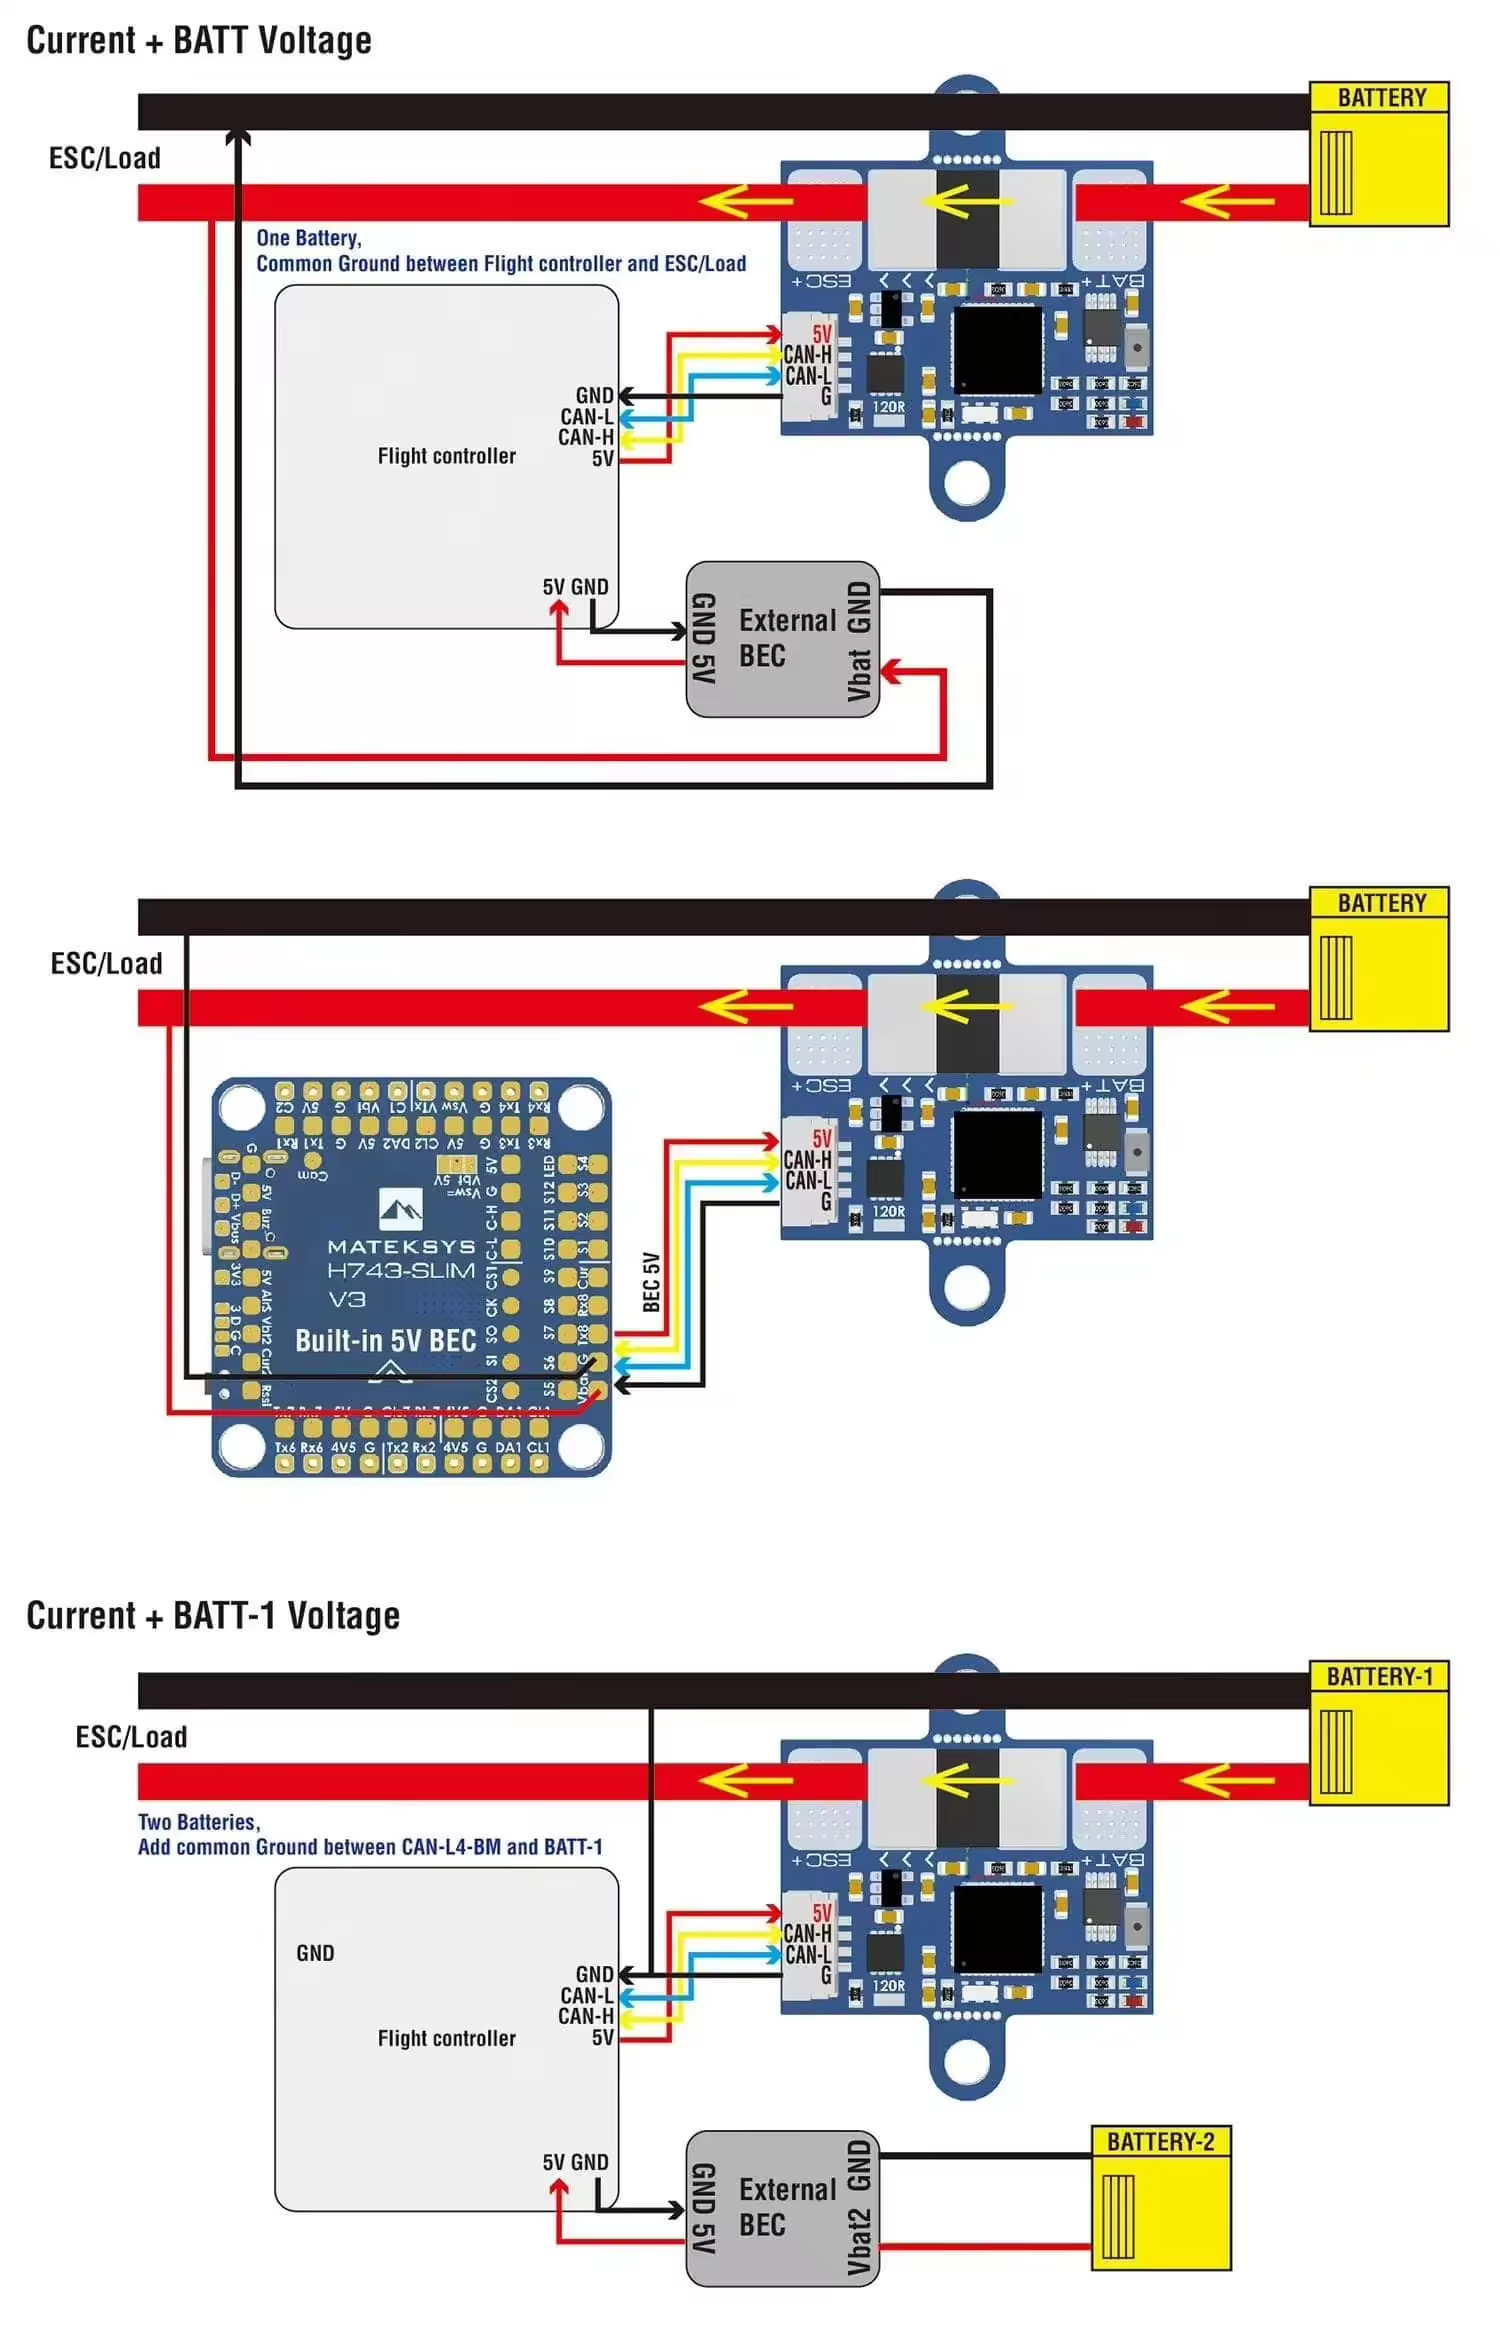
CAN L4 BM Wiring 1

Matek CAN-L4-BM Buying Guide

The Matek CAN-L4-BM is a digital voltage and current monitor for ArduPilot aircraft using DroneCAN. It measures battery voltage up to 85V and current up to 204.8A, then sends the data digitally to the flight controller instead of relying on analog voltage and current-sense wires.

MEPSKING Expert Integration Assessment

From the MEPSKING expert integration perspective, the biggest advantage is the simpler calibration workflow. The INA239 monitoring circuit and AP_Periph firmware transmit digital readings through DroneCAN, so builders do not normally need to adjust the voltage multiplier and current scale required by many analog power modules.

This is particularly valuable on long-range multirotors, fixed-wing aircraft and professional UAVs where accurate battery information is used for telemetry and low-battery failsafes. The 200μΩ sensing path also keeps electrical loss low while supporting a published 150A continuous load.

The practical limitation is equally important: the CAN-L4-BM is a power monitor, not a flight-controller power supply. It requires a regulated 4.5–5.5V input and does not replace a suitable BEC or autopilot power source.

Do You Need a DroneCAN Power Monitor?

ApplicationRecommendationReason
ArduPilot Long-Range UAVRecommendedAccurate battery telemetry and failsafe data
High-Current Multirotor or VTOLStrongly RecommendedMeasures up to 150A continuous and 204.8A burst
Basic Betaflight Freestyle QuadUsually UnnecessaryESC telemetry or an analog sensor is often sufficient
Flight Controller Without DroneCANDo Not ChooseA compatible CAN interface and firmware are required

Compatibility and Setup Checklist

● Confirm that the flight controller supports DroneCAN and ArduPilot AP_Periph. The Matek H743-Slim V4 Flight Controller provides a dedicated CAN connection and does not include its own current sensor.

● Supply the monitor with regulated 5V power. Do not connect battery voltage directly to its 5V input.

● Solder the positive power wires close to both sides of the current-sensing resistor. Use wiring and connectors rated for the aircraft's maximum current.

● For current readings above 90A, update from AP_Periph V1.7.0 or older firmware and configure BATT_MAX_AMPS = 204.8 and BATT_SHUNT = 0.0002.

● Enable the 120Ω termination jumper only when the module is positioned at the end of the CAN bus and termination is required.

Is the CAN-L4-BM Worth Buying?

Buy the Matek CAN-L4-BM when you need dependable digital battery telemetry for an ArduPilot long-range, VTOL or high-current UAV. Its main value is accurate DroneCAN reporting, minimal calibration work and support for high-voltage power systems. For a simple FPV quad without DroneCAN, it adds complexity without providing a meaningful advantage.

Specifications

● MCU: STM32L431xC, 256KB Flash

● INA239 85-V, 16-Bit, High-Precision Power monitor IC With SPI Interface

● Battery Voltage sense input: 0~85V

● Current Sense Range: 0~204.8A

● Load current on current sensing resistor: 150A(Continuous), 204.8A(Burst)

● Voltage accuracy: ± 0.1%

● Current accuracy: ± 2%

● Interface: CAN, DroneCAN Protocol, U-ART2, spare, DFU, -ST debug, SWCLK & SWDIO

● LED: Blue, (Fast blinking, Booting), Blue, (Slow blinking, working) Red, (3.3V indicator)

● Power supply for CAN-L4-BM board: 4.5~5.5V @5V pad/pin

● Power consumption: 10mA

● Operating Temperatures: -40~85 °C
Board Size: 30mm x 22mm x 3mm.

● Weight: 4g

● Firmware: ArduPilot AP_Periph  MatekL431-BattMon

 Update: via DroneCAN GUI Tool

● Parameters: CAN_P1_DRIVER = 1 if attached to CAN bus1 port or CAN_P2_DRIVER = 1 if attached to CAN bus2 port, BATTx_MONITOR = 8 (DroneCAN-BatteryInfo)


Recommendation

Reviews
  • A*******t
    Verified

    Accurate voltage and current readings right out of the box. DroneCAN integration was quick and required no calibration.

    Specification:CAN L4 BM
  • A*******r
    Verified

    Excellent power monitor for ArduPilot builds. The readings stay consistent even during high current flights.

    Specification:CAN L4 BM
  • D***********r
    Verified

    Handles high-current applications very well and provides clean telemetry for my Pixhawk setup.

    Specification:CAN L4 BM
  • U*****h
    Verified

    Installation was straightforward with the JST-GH cable included. Firmware update was simple using DroneCAN GUI.

    Specification:CAN L4 BM
  • T*******r
    Verified

    Great value for anyone building a DroneCAN system. Documentation made installation much easier.

    Specification:CAN L4 BM
  • S*******r
    Verified

    Compact, lightweight, and very accurate. A great choice for larger UAVs using DroneCAN.

    Specification:CAN L4 BM
  • R********r
    Verified

    Build quality is excellent and the CAN communication has been completely reliable so far.

    Specification:CAN L4 BM
  • L**********V
    Verified

    Firmware configuration took a few minutes, but once completed everything worked flawlessly.

    Specification:CAN L4 BM
  • 1
  • 2
FAQ Feel free to ask us any questions